Edge AI
Run bounded inference close to the machine on appropriate MCU, NPU, GPU or edge compute, reducing dependence on continuous cloud connectivity where the workload permits it.
Physical AI / Edge execution infrastructure
A physical execution layer for machines: local intelligence, sensing and consequence control connected through a governed path from observation to real-world effect.
Intelligence can propose. VALO controls what reaches the physical world.
The physical world is not an API. State can be stale, incomplete or unsafe. The action path therefore has to survive uncertainty.
The hardware, perception model and actuator can vary. The important invariant is the governed boundary before physical consequence and the evidence after it.
Run bounded inference close to the machine on appropriate MCU, NPU, GPU or edge compute, reducing dependence on continuous cloud connectivity where the workload permits it.
Place a fresh authority and constraint boundary between machine intent and physical effect. A planner or model does not acquire permission merely because it produced an action.
Add sensing, perception and governed action to useful existing equipment instead of requiring wholesale replacement of the installed base.
Preserve what the machine observed, what remained unknown, what action was allowed or denied, and what physical feedback was actually observed after execution.
PHYSICAL EFFECT PATH
The compute class can change. The consequence path must remain explicit.
HARDWARE & REFERENCE TARGETS
These rows describe integration scope, not blanket hardware validation. This web repository contains no device-specific validation evidence for STM32, Nordic, NPU/SoC or edge-GPU targets; they are therefore labelled target or research/evaluation rather than tested.
STM32-class · Nordic-class
Bounded sensing, local preprocessing and control-adjacent integration where workload, memory and timing constraints permit. Device-specific performance and safety remain to be validated.
NPU / SoC class
Local perception and inference close to the machine, with VALO Physical governing the transition from proposed consequence to authorized effect.
GPU-class edge compute
Target for higher-throughput perception and multi-model workloads. No hardware-specific benchmark or interoperability claim is made here.
Industrial controllers · vehicle compute
Reference target for systems where physical effects cross safety, operational and regulatory boundaries. Validation is installation-specific.
REFERENCE IMPLEMENTATIONS / DEMONSTRATORS
The established architecture requires externally consequential paths to cross current authorization, enforcement and evidence capture. This is implementation-level governance evidence, not proof for a named hardware target.
Inspect the architecture →Applied research for adding sensing, local intelligence and governed action to installed equipment. Hardware-specific validation remains target-dependent.
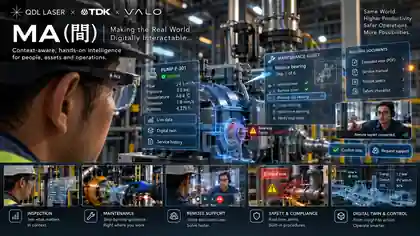
Open research track →MA is a reference architecture and proving ground for making physical environments digitally interactable. It is not a separate VALO product family and does not establish completed partner hardware integration.
Open MA →PHYSICAL INVARIANTS
NO_DIRECT_EFFECT_PATHNo ungoverned causal route to consequence.NO_DETECTION ≠ SAFEFailure to detect a hazard is not evidence of safety.Capability ≠ AuthorityA machine's ability to act never creates its right to act.VERTICAL PROFILES
These are deployment profiles over the same VALO Physical consequence path, not separate product stacks.
VALO Physical is the product surface. Universal Retrofit Intelligence remains the applied research track for retrofit architecture. Edge / MCU / NPU remains a technical substrate, not a standalone product.
Local sensing and inference can reduce latency, bandwidth and cloud dependence. They do not themselves grant a right to move a machine, open a valve, energize equipment or create another physical effect.
VALO Physical carries the Machine Action Infrastructure principle into the physical world: intelligence proposes; current authority and constraints govern consequence; evidence records the result.
Status: product architecture assembled from active VALO execution-governance work and applied edge/retrofit research. Hardware-specific performance, safety, interoperability and regulatory claims require validation on the selected device and deployment.